Workspace matched to the task.
Cable lengths, anchor geometry and supporting structure define the workspace. Payload, cable forces and motion profiles are designed together.
CABLE ROBOTICS FOR INDUSTRY
One platform. Two applications.
Versatile handling in machine engineering and plastic 3D printing.
Developed for tasks that need room.
Technology in development.
Designed for your process.
01 / THE APPLICATIONS
The task comes first. Our cable robot platform is being developed for two industrial applications, each with suitable tools, parameters and evidence.
A cable robot platform for versatile handling tasks in machine and plant engineering, with a gripper or tool tailored to the process.
Explore handling applications 02 / 3D PRINTINGPlastic 3D printing for prototype parts, fixtures and custom geometries. Printhead and process are designed for PLA, PETG, PA6, PA12 or other suitable plastics.
Explore plastic printing02 / THE PLATFORM
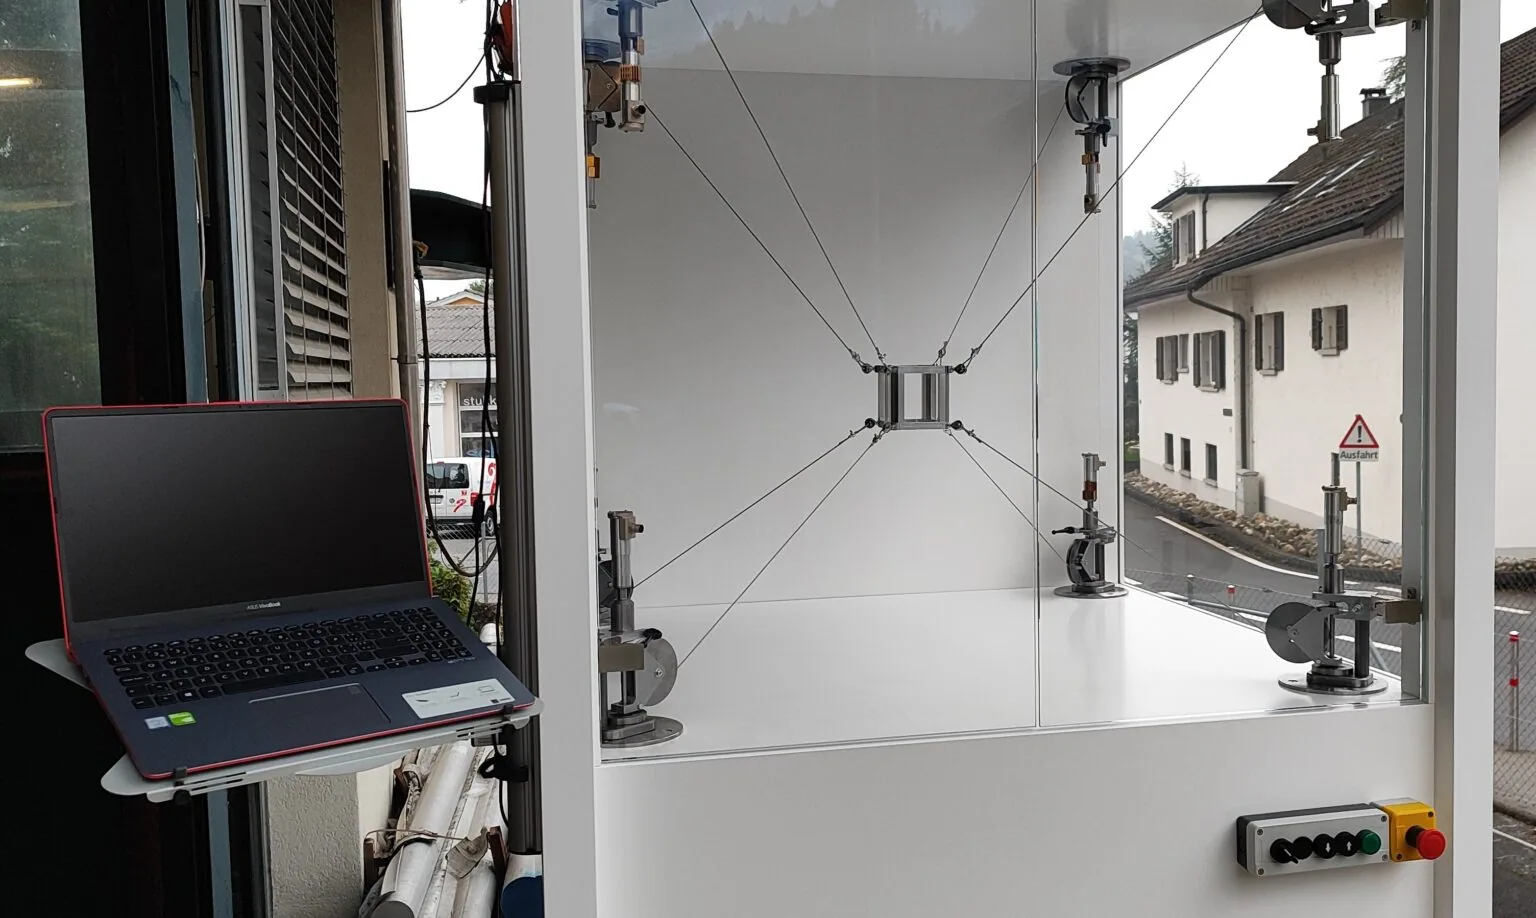
Eight separately controlled cables guide a lightweight central platform. Six degrees of freedom combine position and orientation. Drives remain at the anchor points; the tool is selected for the task.
Cable lengths, anchor geometry and supporting structure define the workspace. Payload, cable forces and motion profiles are designed together.
The lightweight platform offers potential for dynamic motion. In handling applications, the gripper and workpiece also contribute to the moving mass.
A gripper for handling or an extruder for plastic printing: tool mounting, supply and control are developed for each process.
CABLE ROBOTICS / INTERACTIVE PRINCIPLE
Ready to moveIllustration of the principle with example movements, not a simulation of an actual machine. Design, cable tension and accuracy are specified for each application.
THE NEXT IMPLEMENTATION
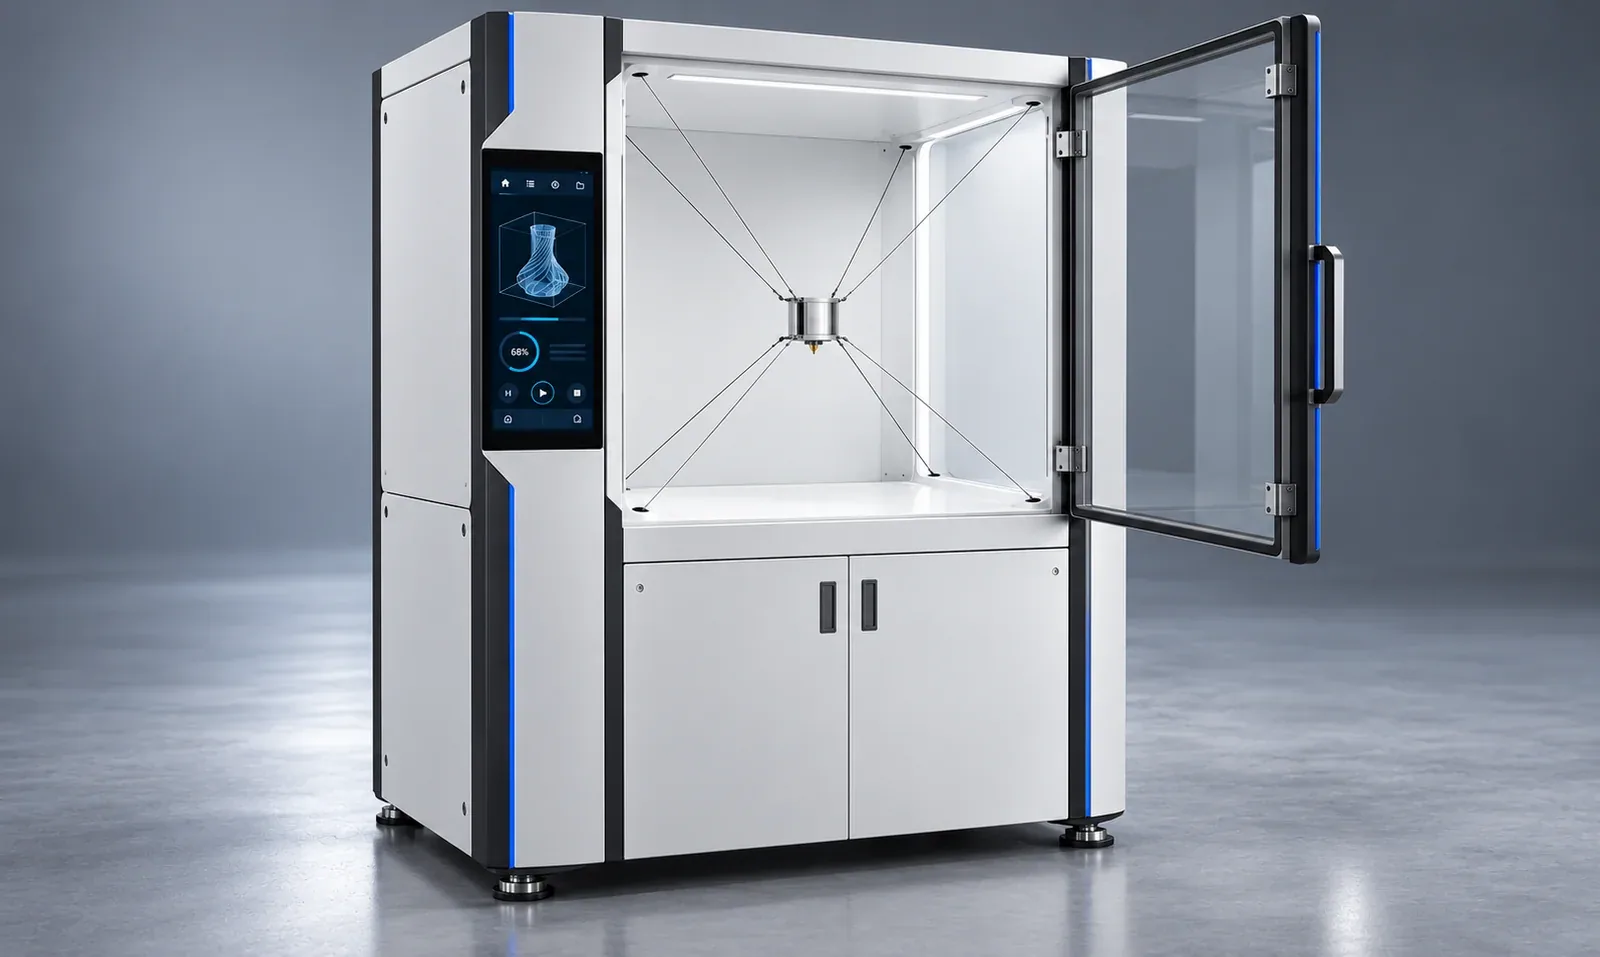
The printer design study shows a planned implementation with integrated controls, enclosed drives and an accessible workspace. For handling tasks, tools, supporting structure and the installation environment are designed separately.
Explore the design study03 / FOR INDUSTRIAL CUSTOMERS
Machine builders, plant engineers and manufacturers: describe your task. We assess the requirements cable robotics must meet.
Dimensions, weight, centre of gravity and gripping points.
Transfer positions, travel, orientation and obstacles.
Target cycle, positioning requirement and permissible vibration.
Gripper, interfaces, access and the safety concept of the complete installation.
04 / OTHER TRIMED PRODUCTS